Rack & Pinion for Robot Travel and 7th Axes
A robot seventh axis adds long linear travel to a robot that already produces rapid acceleration, frequent reversals and changing payload moments. The rack, pinion and gearbox interface should therefore be treated as one drivetrain rather than as separate catalogue items.
랙 드라이브가 해야 할 일
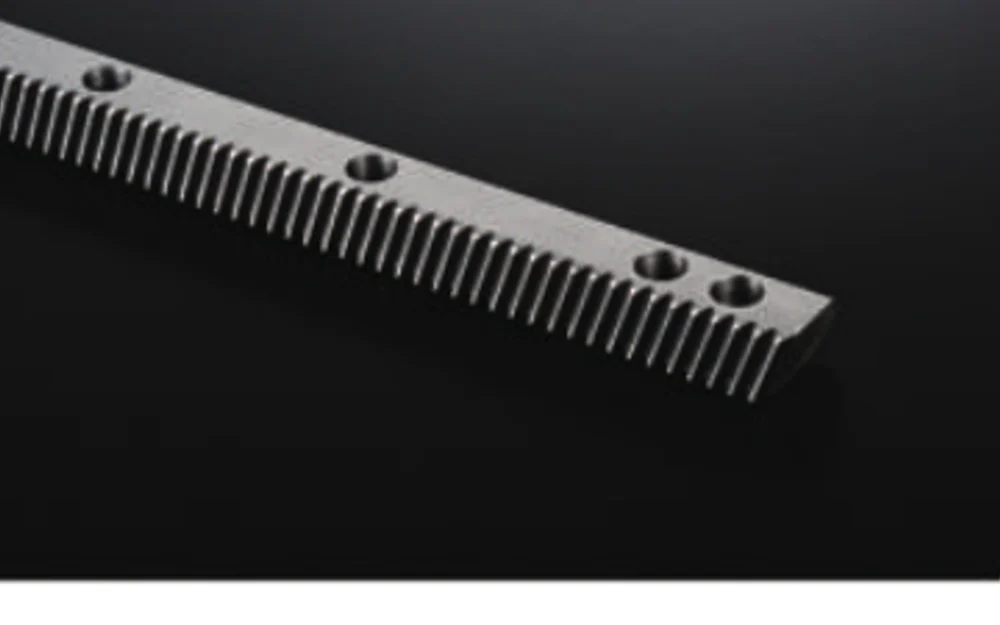
Smooth meshing is valuable when the robot repeatedly changes direction or approaches programmed points at speed. Helical rack-and-pinion systems are often considered for that reason, while the final decision still depends on load, positioning target, mounting stiffness and the control strategy.
해당 애플리케이션은 완전한 축으로 설명되어야 합니다. 즉, 랙 톱니 시스템, 피니언, 기어박스 인터페이스, 장착 베이스 및 윤활 방식을 모두 함께 검토해야 하며, 랙 자체만으로 성능을 결정한다고 가정해서는 안 됩니다.
부품을 고정하기 전에 기계의 작동 조건을 정의하십시오.
이러한 입력값들은 단순히 기하학적 정보만을 기반으로 한 견적과 드라이브의 실제 사용 방식을 반영한 견적 사이의 차이를 만들어냅니다.
| Travel | Total rail length and whether one or multiple rack sections are needed. |
|---|---|
| Robot system mass | Robot, base, dress pack, tooling, fixture and maximum payload. |
| Dynamics | Acceleration, deceleration, reversal rate and emergency-stop load case. |
| Accuracy | Repeatability along the rail, backlash target and calibration strategy. |
| Drive packaging | Gearbox orientation, pinion support, motor brake and cable-management envelope. |
이 용도에 대해 일반적으로 평가되는 제품
아래 선택 사항은 시작점일 뿐이며 자동 선택이 아닙니다. 최종 적합성은 도면 및 작동 데이터에 따라 달라집니다.
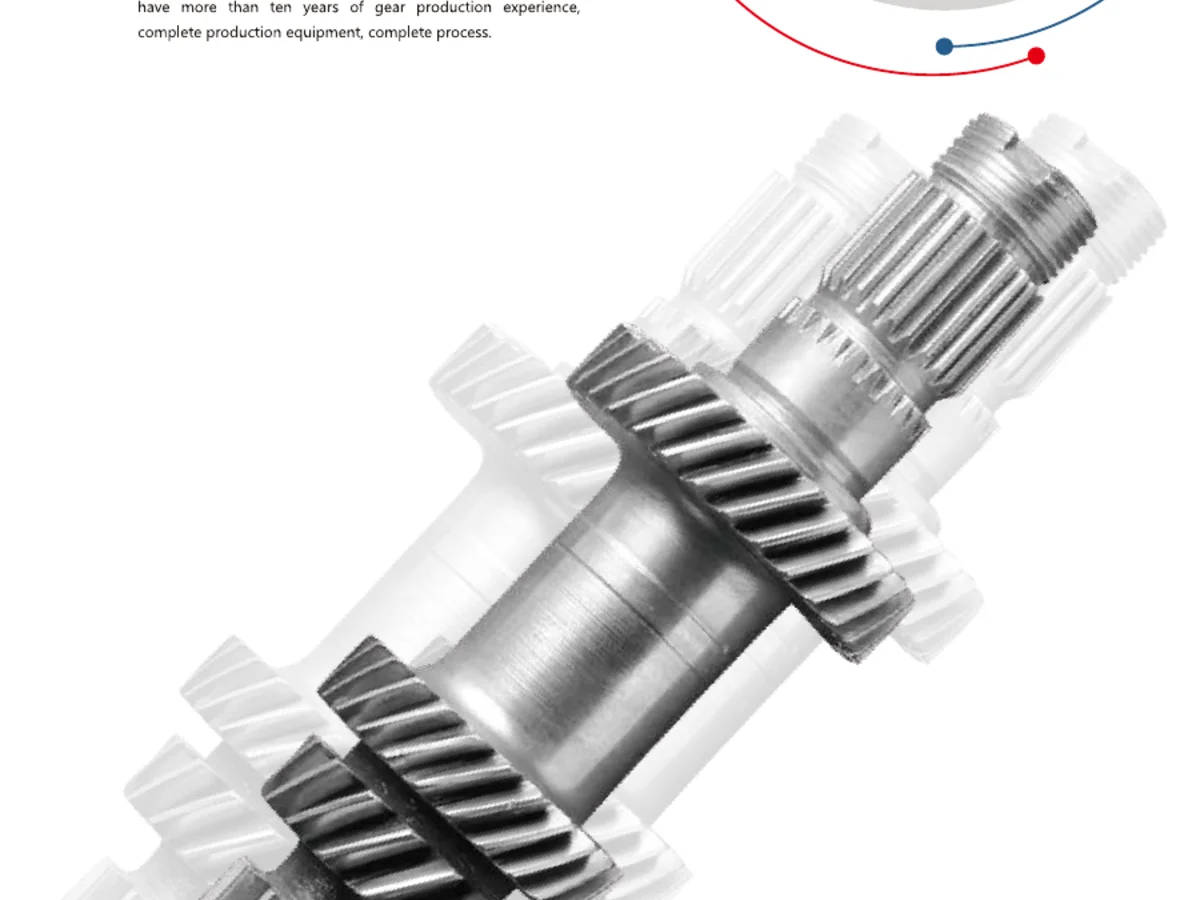
설치 세부 사항은 정밀 랙의 가치를 없애거나 유지할 수 있습니다.
Support the pinion and gearbox so that robot acceleration does not deflect the mesh out of alignment.
Provide a practical way to set and re-check engagement after installation or maintenance.
Protect the rack from welding debris, grinding dust or floor contamination where the rail crosses active production areas.
지원 문의 시 함께 보내실 정보
Include robot model/mass, maximum payload, rail travel, target speed and acceleration, duty cycle, required repeatability, gearbox output details and the preferred rack mounting arrangement. For dual-drive or master/slave axes, identify how the two sides will be synchronized.
아직 확정되지 않은 값이 있다면 설계 목표로 표시하세요. 이는 나중에 변경하기 어려워지는 추측에 기반한 사양을 입력하는 것보다 훨씬 유용합니다.
해당 부품을 정의하는 세부 정보를 보내주세요.
정확한 견적을 위해서는 먼저 장치의 형상과 작동 환경을 명확히 제시해야 합니다. 도면, 수량, 그리고 요구되는 사양을 보내주십시오. 랙 구동 방식의 경우, 이동 거리, 속도, 가속도, 하중, 그리고 가능하다면 연결 피니언 또는 기어박스 정보도 함께 보내주시기 바랍니다.
주문하기: 최소 주문 수량(MOQ)은 제품 유형 및 주문 금액에 따라 유연하게 조정 가능합니다. 신규 고객 샘플은 1~5개부터 주문 가능하며, 여러 모델을 혼합 주문하는 경우 총 주문 금액이 미화 1,500달러 이상이면 지원됩니다. 1~2개 주문 시에는 단가가 더 높게 책정될 수 있습니다.
시기 및 조건: 표준 부품은 일반적으로 10~25영업일, 맞춤형 부품은 20~45영업일, 프로젝트 장비는 45~120일이 소요됩니다. EXW, FOB, CIF 및 DAP 조건이 일반적으로 제공되며, FCA, CFR, CPT, CIP 및 DDP 조건은 개별 사례에 따라 협의 가능합니다.